01
Scarce
There is very little robot training data in the world, and it cannot be copied from the web.
SUPPLY / LIMITEDBittensor subnet / Robot data from your phone
Robots learn by being shown what to do, and that data is hard to get cheaply. Talos lets anyone with a phone drive a simulated robot arm, earn for good runs, and help build open training data for robots.
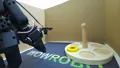
Task Insert the colourful ring into the central wooden peg.
The problem
Chatbots learn from text on the internet. Robots cannot. Someone has to show a robot each move, and today that means real robots, trained operators and a big budget.
There is very little robot training data in the world, and it cannot be copied from the web.
SUPPLY / LIMITEDCollecting it needs a robot lab and paid operators, at up to $200 for one usable hour.
COST / HIGHA few companies collect the data and check their own work. Everyone else has to take their word for it.
ACCESS / CENTRALIZEDThe solution
Open a task and steer a simulated robot arm. It moves just like the real one.
When you finish, your run goes to the network to be checked.
Validators use RoboJev to score how good the run was. Bad or fake runs are rejected.
Good runs earn rewards and join a dataset that companies use to train robots.
Why a phone
The phone runs the same physics as a real SO-101 robot arm. Anyone with a phone can make useful robot data and earn from it, without owning a robot.
Explore the SO-101
Drag to orbit. Use + / − to zoom.
Why Bittensor
Bittensor rewards people for doing useful work and other people for checking it. That lets Talos run with no single company in charge.
Collect robot data by playing tasks on a phone, and earn for every run that passes.
COLLECT / EARNCheck each run with RoboJev and earn for scoring fairly.
CHECK / EARNBuy checked, ready-to-train robot data without running their own robot lab.
BUY / TRAINLive network
These are real runs from players, moving through the network as they are checked.
Network activityFetching current network activity…
Open networkQuality is measurable
input = video + robot motion
output = quality score, 0 to 1
RoboJev watches the recorded video and the robot movement across each dataset, then scores how good the teleoperation data is from 0 to 1. Runs must also replay and be meaningfully original.
Explore verified datasetsGet started